Goals That Think: Designing for Distributed Reasoning
In most tools, a goal is a static record: a title, a due date, maybe a progress bar that waits for you to remember it, decide what to do, and supply all the effort. The thinking is entirely yours, and thinking is often the resource you run out of first.
We took a different stance: a goal should carry some of the thinking. In practice, that means keeping useful context, noticing a pattern, and putting one small next step within reach.
Cognitive scientists have spent decades showing that thinking is not sealed inside your skull. Edwin Hutchins, studying how navigators steer a ship, described distributed cognition as reasoning spread across people, instruments, and the environment rather than concentrated in one head. Andy Clark and David Chalmers pushed the idea further with the extended mind, where a notebook, calendar, or well-designed tool can become part of your cognitive process, more than a place to store its output.
If reasoning can be offloaded to the environment, a goal system should carry some of it. Bolting a chatbot onto a task does not go far enough. Each goal needs a small, persistent reasoner with a narrow job: remember relevant context, watch patterns over time, offer a next step when the signal is strong, and stay quiet when it has nothing useful to add.
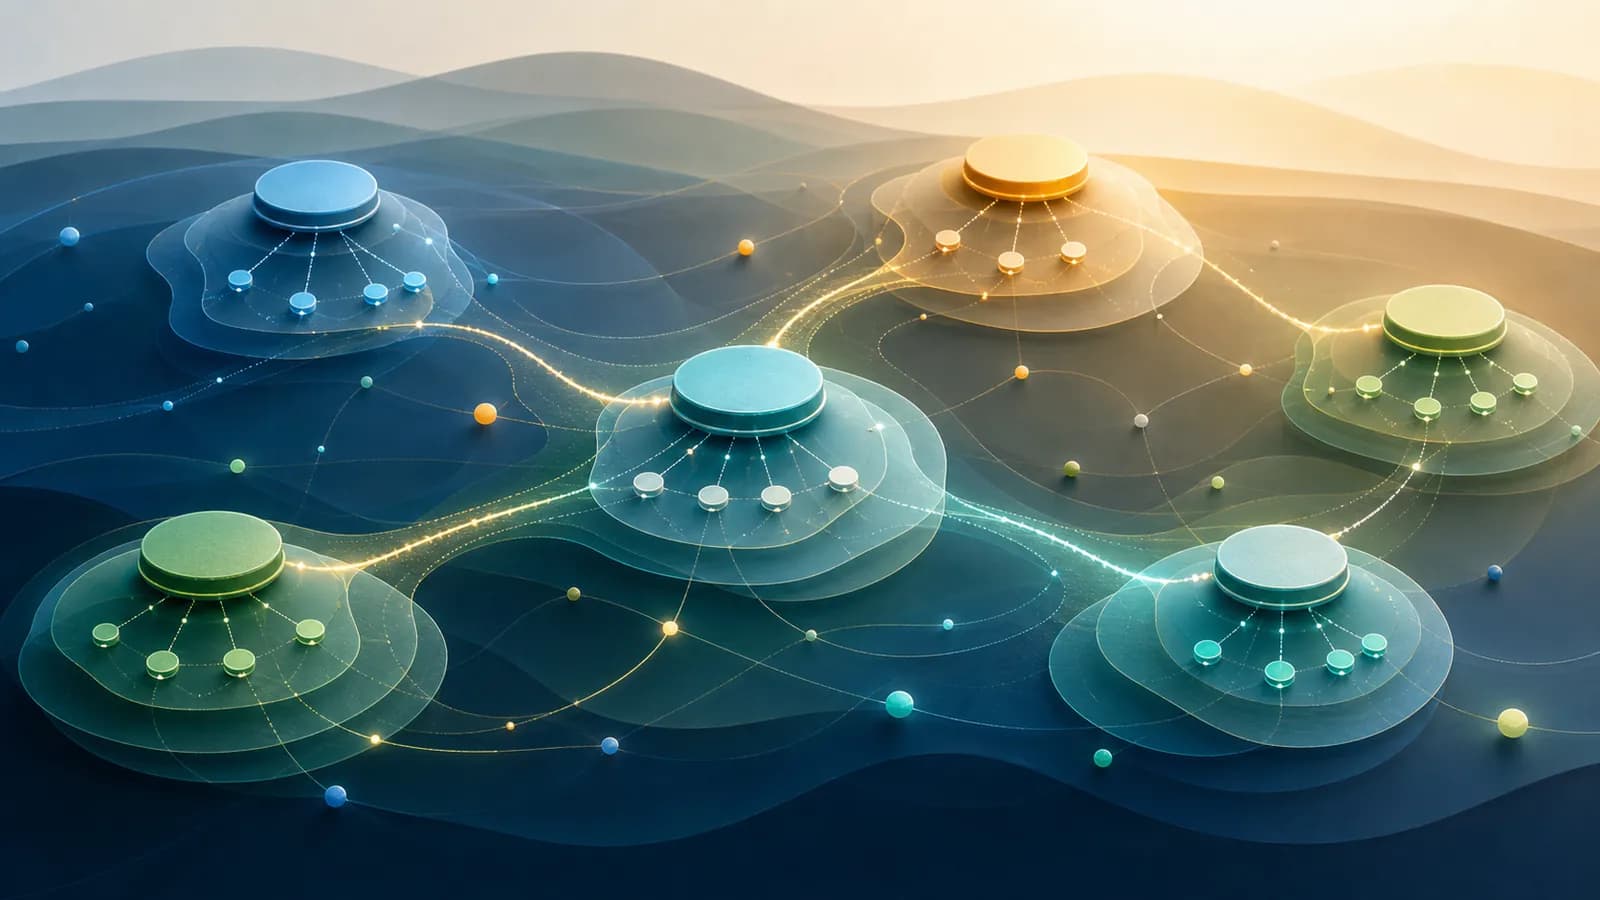
Things get more interesting when goals can think together. Machine learning has a long thread on ensembles, where several narrow models can be more robust than one model trying to do everything. The parallel is loose, but useful: each goal reasons within its own scope, without depending on one master plan that breaks when life changes.
Goals can also compare notes. Progress on sleep can inform what is realistic for training. An overloaded week in one area can soften the push in another. Useful connections surface from the overlap, including some that no single goal could have made alone.
You are not leaning on one clever assistant, either. Each goal is backed by specialist reasoners watching timing, realism, recovery, friction, or the tension between goals that want the same hours. Add the agents that look across your whole set, and you get a small society quietly attending to your goals. Most of it stays underneath and passes up only what is worth your attention, while Coach, Advisor, Zen Guide, and Buddy translate the signal into something usable.
Trust requires an audit trail. A goal that thinks should show the recent signals, assumptions, and other factors behind a suggestion. You still make the call, with something concrete to inspect first.
The limits matter. A goal cannot know about a constraint you never shared, and it may misread a quiet week. This approach suits the everyday work of staying connected to a goal. Deeper strategic calls still need you, a mentor, or time to reflect. Annet should make ambition easier to act on, while leaving the ambition itself to you.
How Annet applies this
This is the core of how Annet works rather than a feature bolted on top. Each goal reasons in the background, compares useful signals with the rest of your goal set, and lets specialist agents pass up only what deserves attention.
The visible layer stays intentionally calm because Coach, Advisor, Zen Guide, and Buddy translate the underlying reasoning into guidance you can use quickly, while expanded perspectives let you inspect why a recommendation appeared when you want more context.
References (starting points)
This post is a practical synthesis. For the original ideas and evidence, start here.
- Hutchins, E. (1995). Cognition in the Wild. MIT Press.
- Clark, A., & Chalmers, D. (1998). The extended mind. Analysis, 58(1), 7-19.
- Dietterich, T. G. (2000). Ensemble methods in machine learning. Multiple Classifier Systems, 1-15.
- Kirsh, D., & Maglio, P. (1994). On distinguishing epistemic from pragmatic action. Cognitive Science, 18(4), 513-549.